Description
Ramp the pulse command to vary wheel speed during starts, stops and turns.
Specifications
- 0–50 RPM
- 4–6 V DC supply
- Four mounting screw positions
$23.35
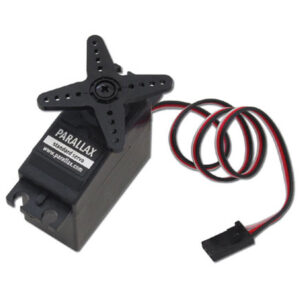
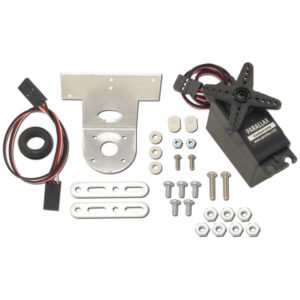
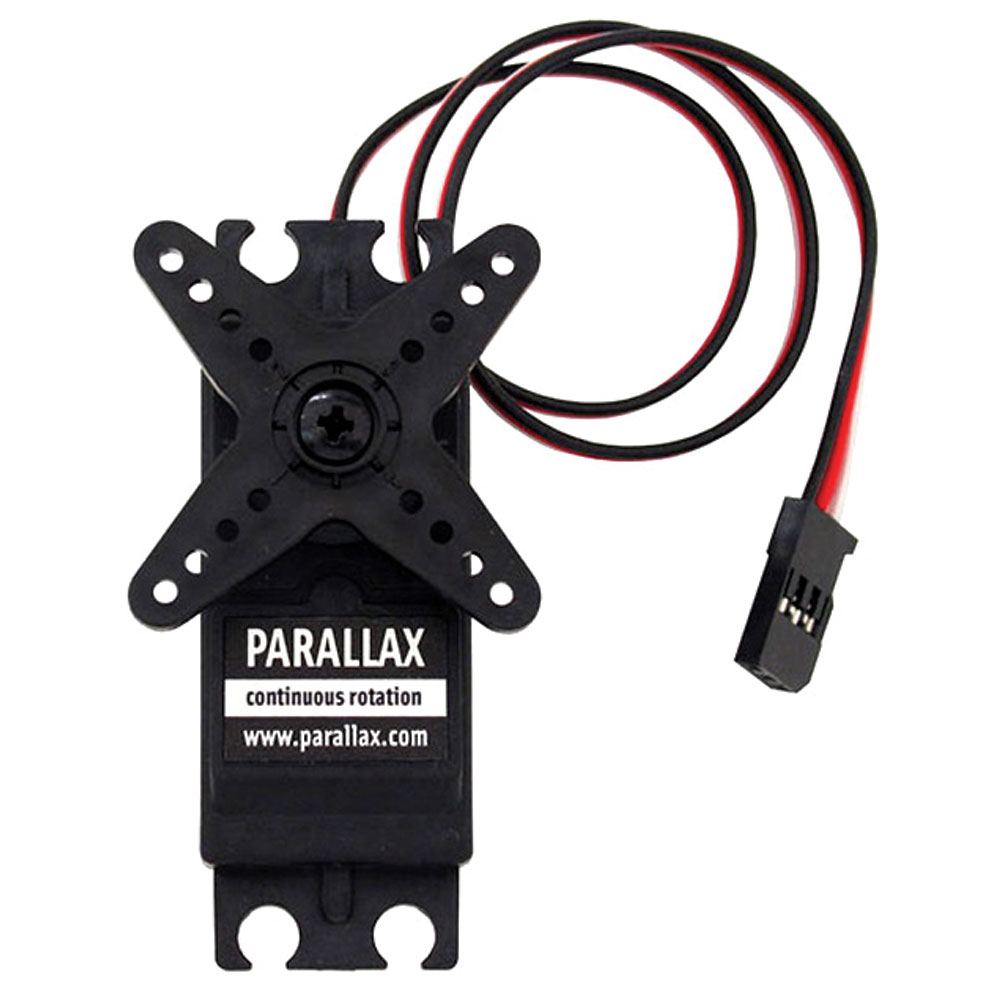
Drive a robot wheel forward or backward with a continuous-rotation servo. A PWM signal controls direction and speed.
Ramp the pulse command to vary wheel speed during starts, stops and turns.
Drive a wheel continuously while measuring its angular position. A dedicated feedback line reports position from the internal Hall-effect sensor.
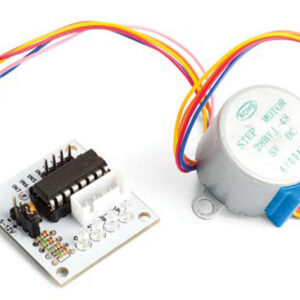
Add geared motion to an Arduino-compatible project. The set pairs a 5 V stepper motor with its ULN2003 driver board and cable.
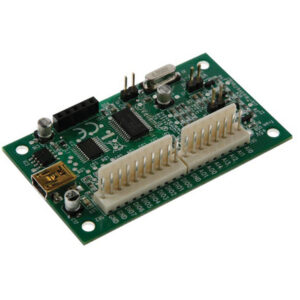
Add computer-controlled analog inputs and digital I/O to existing equipment. The assembled board draws power and exchanges data through USB.
Reviews
There are no reviews yet.